 Owen Bradley
A robot vacuum is wonderful until it eats a phone charger, redistributes the cat’s water bowl across the kitchen, or wedges itself under the sofa for the third time this week. No-go zones exist to prevent exactly that, and on paper they are simple: draw a box on the app map, the robot stays out. In practice people find the zones drift, get ignored, or vanish entirely after the robot re-maps a room. That is almost always a mapping problem rather than a software bug. Knowing how the map is built, when it gets rewritten and where the boundaries actually sit is the difference between zones that hold for months and zones you redraw every week. This guide covers setting them up properly, fixing drift and choosing between virtual walls, no-go zones and no-mop zones.
How Robot Vacuums Build a Map
Everything depends on the map, and the map depends on which sensors your robot has. Lidar models spin a laser turret and measure distances to walls and furniture, producing an accurate floor plan that survives changing light conditions. Camera-based models use visual landmarks on the ceiling and around the room, which works well in daylight but degrades in the dark. The cheapest robots have no mapping at all — they bounce semi-randomly, and for those, software no-go zones simply do not exist.
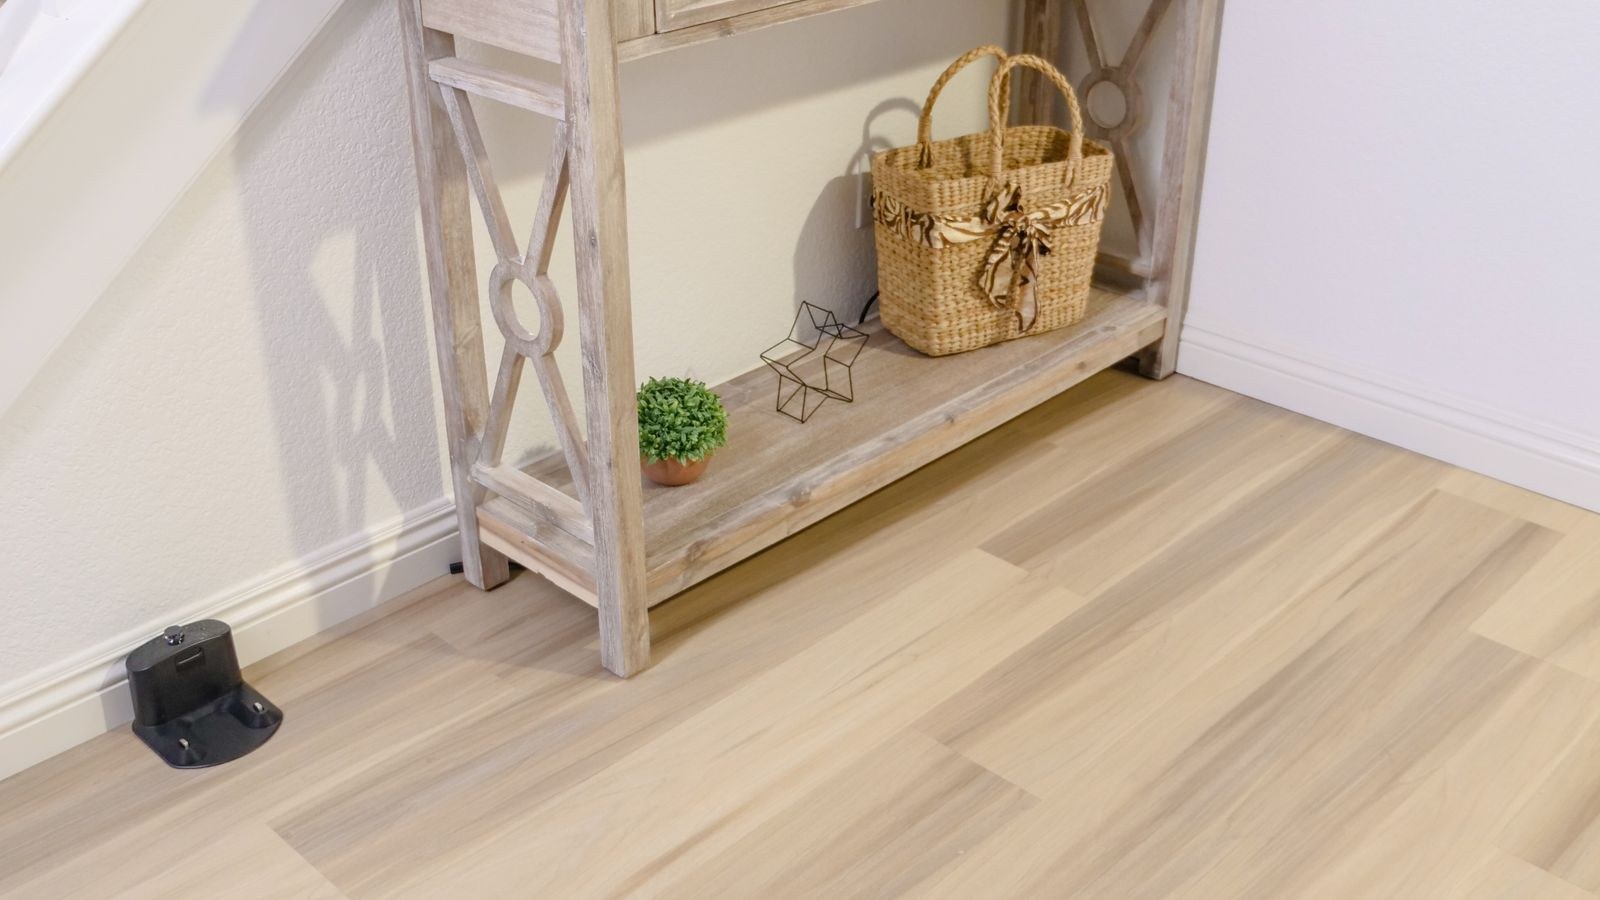
The critical thing to understand is that the map has an origin, and the origin is the dock. The robot works out where it is by leaving the dock and tracking its movement relative to that starting point. Move the dock and every saved zone shifts with it, because the coordinates were never tied to your walls — they were tied to the charging base. That single fact explains most of the “my no-go zones stopped working” complaints you will ever read.
Before You Draw Any Zones
- Pick a permanent dock location against a wall, with clear space either side and in front, and commit to it.
- Tidy the floor completely — cables, socks, toys, shoes, pet bowls — so the first map records the true room shape.
- Open every interior door the robot should be able to reach, and close any it should not.
- Turn the lights on if your robot uses a camera for navigation.
- Update the app and firmware before mapping, since map format changes sometimes force a re-map.
Then run a dedicated mapping or exploration run if your app offers one. It moves faster than a cleaning pass and produces a cleaner outline because the robot is not stopping to deal with dirt.
Step-by-Step: Setting No-Go Zones That Hold
- Complete a full map before drawing anything. Let the robot run until the app shows every room closed off and correctly shaped. Zones drawn on a partial map will land in the wrong place once the map fills in.
- Save and lock the map. Almost every app has a save-map or persistent-map option, and many have a lock or edit-protection setting. Turning it on stops the robot overwriting your carefully edited map on the next run, which is what erases zones for most people.
- Name and split the rooms. Use the room-editing tools to divide open-plan spaces and merge over-split ones, then name each room. Room-level control is often a better solution than a zone — telling the robot to skip the study entirely is simpler and far more reliable than fencing off part of it.
- Draw no-go zones with generous margins. Extend the box roughly 8 to 12 inches beyond the actual hazard on every side. Robots overshoot slightly at speed and localisation is never perfect, so a boundary drawn tight to the object will be crossed. Rectangles work far better than complex shapes, and most apps only support rectangles anyway.
- Use virtual walls for doorways and gaps. A virtual wall is a line rather than an area and is the right tool for a stair opening, a doorway you want closed, or the gap beneath a low sideboard. Draw it a few inches inside the room you want protected, and make it wider than the opening so the robot cannot slip around either end.
- Fence the classic trouble spots. Pet food and water bowls, cable nests behind desks and media units, floor vents, curtain and blind cords, plant pots, shoe racks, freestanding lamps with tripod bases, and any deep-pile rug with a fringe that tangles the brush roll.
- Add no-mop zones separately. If your robot mops, mark rugs, carpet, wood floors and thresholds as no-mop rather than no-go. That lets the robot vacuum them while keeping the wet pad away, which is usually what you actually want.
- Set the multi-floor maps up individually. Each floor needs its own saved map and its own zones. Confirm your model supports multiple maps before carrying it upstairs, and let it identify which map it is on at the start of a run rather than assuming.
- Test with a supervised run. Start a clean and watch what happens at each boundary. Robots frequently clip a corner or approach from an angle you did not anticipate. Widen any zone the robot touches rather than adding a second overlapping box.
- Combine software zones with physical barriers where it matters. For genuinely serious hazards — an open stairwell, an expensive rug, a fish tank stand — put a physical stop in place too. Magnetic boundary strips, a closed door or a small barrier cost nothing and do not depend on the map surviving a firmware update.
Why Zones Drift and How to Fix It
Zone drift happens when the robot’s idea of the origin no longer matches reality. The most common cause is a moved dock, even by a few inches — someone nudges it while vacuuming manually, or it gets shifted to plug something else in. Mark the dock’s footprint on the floor with a strip of tape underneath so it always goes back to exactly the same spot.
The second cause is a lost robot. If you carry it back to the dock manually mid-run, or it starts a cycle from somewhere other than the base, some models fail to relocalise and quietly build a new map that overwrites the old one. Always send it home through the app instead of picking it up, and if you must move it, put it back roughly where you found it.
Large furniture rearrangements are the third cause. Lidar matches what it sees against the saved map, and if a room’s outline changes substantially the match fails and the robot re-maps. After a big rearrangement, expect to re-map and redraw zones deliberately rather than hoping the old ones still apply. Cleaning the lidar turret window and the cliff sensors with a dry cloth every few weeks also helps considerably, because a dusty sensor produces sloppy distance readings and sloppy boundaries.
Common Mistakes
- Drawing zones before the map is complete. Every boundary shifts when the missing rooms fill in.
- Leaving the map unsaved or unlocked. The next run overwrites it and your zones disappear.
- Drawing the box tight to the object. Allow a foot of margin; robots overshoot.
- Moving the dock. Every zone is measured from it, so the whole set shifts.
- Using no-go where no-mop was needed. Rugs end up never vacuumed at all.
- Trusting software alone near stairs. Always back it up with a physical barrier.
- Fencing off a problem you could tidy. A cable clipped to the wall beats a permanent no-go zone.
When the Robot Cannot Do Zones Well
Not every robot handles boundaries equally. Random-navigation models have no map and therefore no zones at all — for those, physical barriers or boundary strips are the only option. Camera-based navigation is workable but tends to drift more in low light. Lidar models with persistent, editable, multi-floor maps are far and away the most reliable, and if precise zone control matters to you it is the feature to shop on.
If your current machine cannot hold a map, upgrading is the honest answer. Our comparison of the best robot vacuums and mops covers which models offer proper no-mop as well as no-go control, while the robot vacuum buying guide explains the navigation types in detail so you can tell mapping-capable models from bump-and-turn ones before you buy. For hands-off operation, the units in our best self-emptying robot vacuums roundup pair persistent maps with base stations that empty the bin for weeks at a time, and the wider best robotic vacuum cleaners and best iRobot vacuums lists compare app quality, which matters enormously when you are editing maps regularly.
Frequently Asked Questions
Do no-go zones work if the robot starts away from the dock?
Usually yes on lidar models, which relocalise by matching what they see to the saved map. Camera-based robots are less reliable at this, and cheaper models may ignore zones entirely until they return to the base. Starting from the dock is always the safest option.
What is the difference between a virtual wall and a no-go zone?
A virtual wall is a line the robot will not cross, best for doorways and stair openings. A no-go zone is an enclosed area the robot will not enter, best for fencing off an object or a corner. Use lines for openings and boxes for hazards.
Why does my robot still bump the edge of a zone?
Boundaries are approximate, and localisation error of a few inches is normal. Widen the zone by another six inches on the side it keeps touching rather than adding a second overlapping box, which some apps handle poorly.
Will a firmware update erase my zones?
It can, particularly major updates that change the map format. Export or back up your map through the app if that option exists, and check your zones after any significant update before running an unsupervised clean.
Are magnetic boundary strips still useful?
Very much so, especially for stairs, pet feeding areas and rugs you never want touched. They work regardless of firmware, map state or dock position, which makes them the right backup for anything you genuinely cannot risk.
Final Thoughts
Reliable no-go zones come down to a stable foundation rather than clever drawing. Fix the dock in one permanent spot, build a complete map on a tidy floor, save and lock it, then draw generous rectangles around the hazards and use virtual walls for doorways and stair openings. Choose no-mop instead of no-go wherever the issue is water rather than the robot itself, test everything with one supervised run, and put a physical barrier behind the boundaries that really matter. Set it up carefully once and you will spend the rest of 2026 listening to the robot work instead of rescuing it from under the couch.